[In review]
Role of Kinesthetic Force Magnitude in Motor Learning After-Effects
Eugenio Frias-Miranda, Mackenzie M. Matthews, Mackenzie R. Misterka, Deva D. Chan, and Laura H. Blumenschein, [In review].
Soft robots leverage compliance, flexibility, and deformation, offering the potential for safe interaction with people and assistance in everyday tasks. However, translating these capabilities into reliable assistance requires overcoming challenges in modeling, sensing, and control, especially for continuum robots whose complex shape changes and nonlinear dynamics make it difficult to predict their behavior and respond to human needs.
My work investigates human–soft robot interaction with the goal of closing the loop between two reciprocal directions: humans helping soft robots and soft robots helping humans.
The central premise of my work is that integrating human (1) perception, (2) interpretation, and (3) decision-making with soft-robot models can create a synergy in which both agents complement one another.
This synergy can enable soft robots to safely assist and learn with people in their everyday tasks.
Below is a list of projects that I have worked on. Feel free to look through them!
I investigate how physical interaction with compliant wearable devices can support motor learning and help people develop lasting improvements in how they move.
Eugenio Frias-Miranda, Mackenzie M. Matthews, Mackenzie R. Misterka, Deva D. Chan, and Laura H. Blumenschein, [In review].
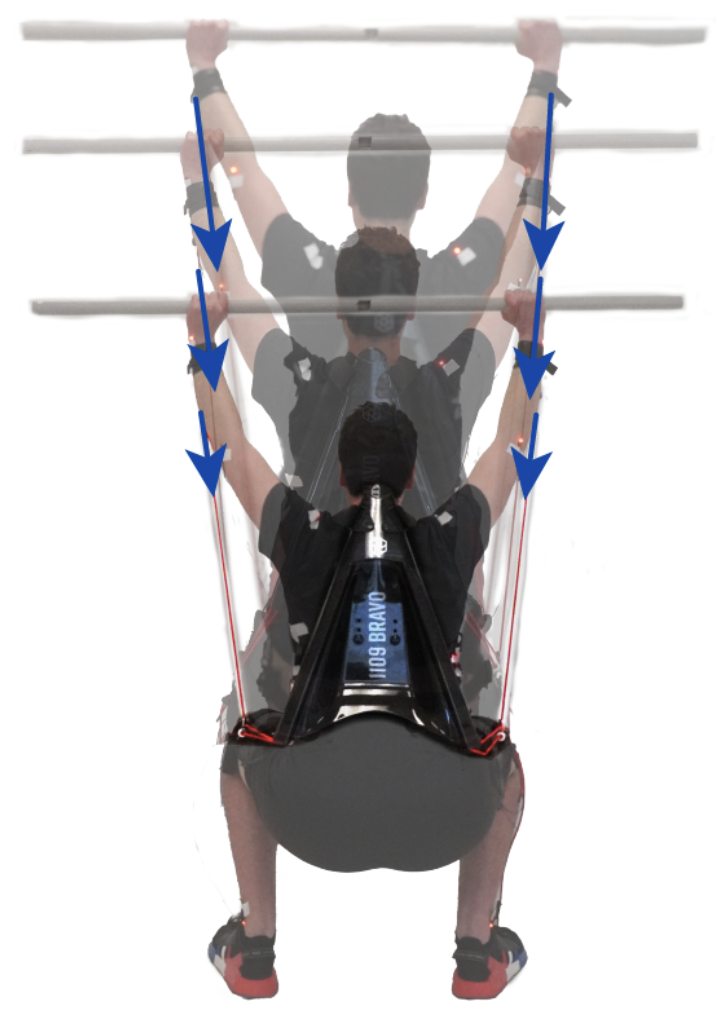
Eugenio Frias-Miranda, Hong-Anh A. Nguyen, Jeremy Hampton, Trenner A. Jones, Benjamin Spotts, Matthew Cochran, Deva D. Chan, Laura H. Blumenschein, 2024 10th IEEE RAS/EMBS International Conference for Biomedical Robotics and Biomechatronics (BioRob), 2024
I explore how human perception, intuition, and decision-making can help soft robots navigate uncertainty and perform tasks that are challenging for modeling and control alone.
Eugenio Frias-Miranda*, Alejandra de la Torre*, Denny Yu, and Laura H. Blumenschein, [Submitted].
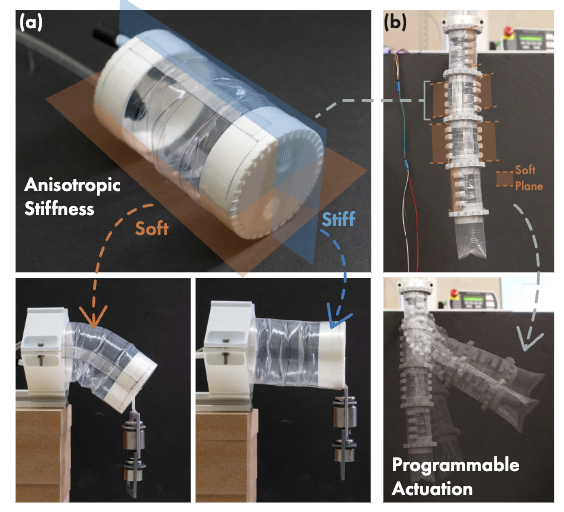
Sicheng Wang, Eugenio Frias-Miranda, Antonio Alvarez Valdivia, Laura H. Blumenschein, 2025 IEEE International Conference on Robotics and Automation (ICRA), 2025
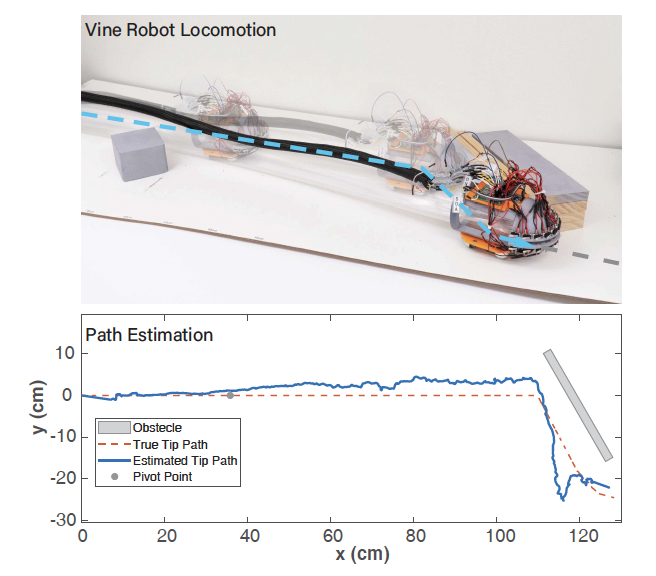
Eugenio Frias-Miranda, Alankriti Srivastava, Sicheng Wang, Laura H. Blumenschein, 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
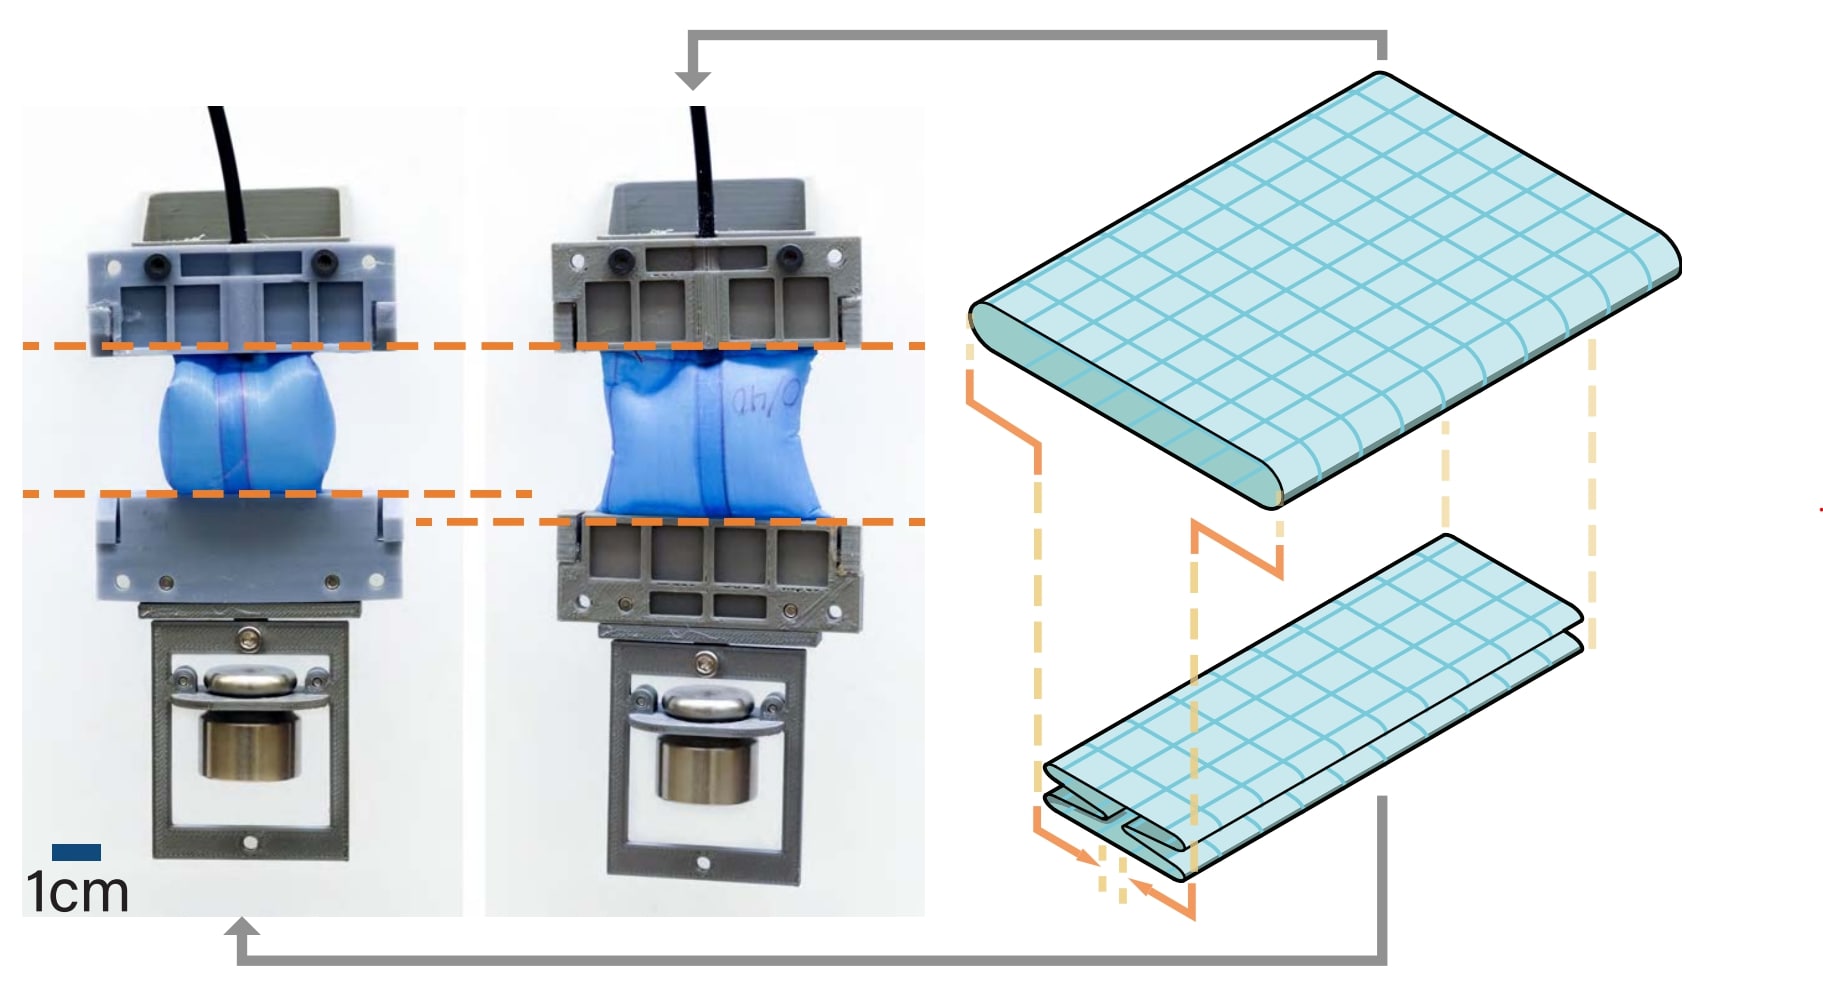
Sicheng Wang, Eugenio Frias-Miranda, Laura H. Blumenschein, IEEE Robotics and Automation Letters, 8(3), 1383-1390, 2023